Stack


Overview
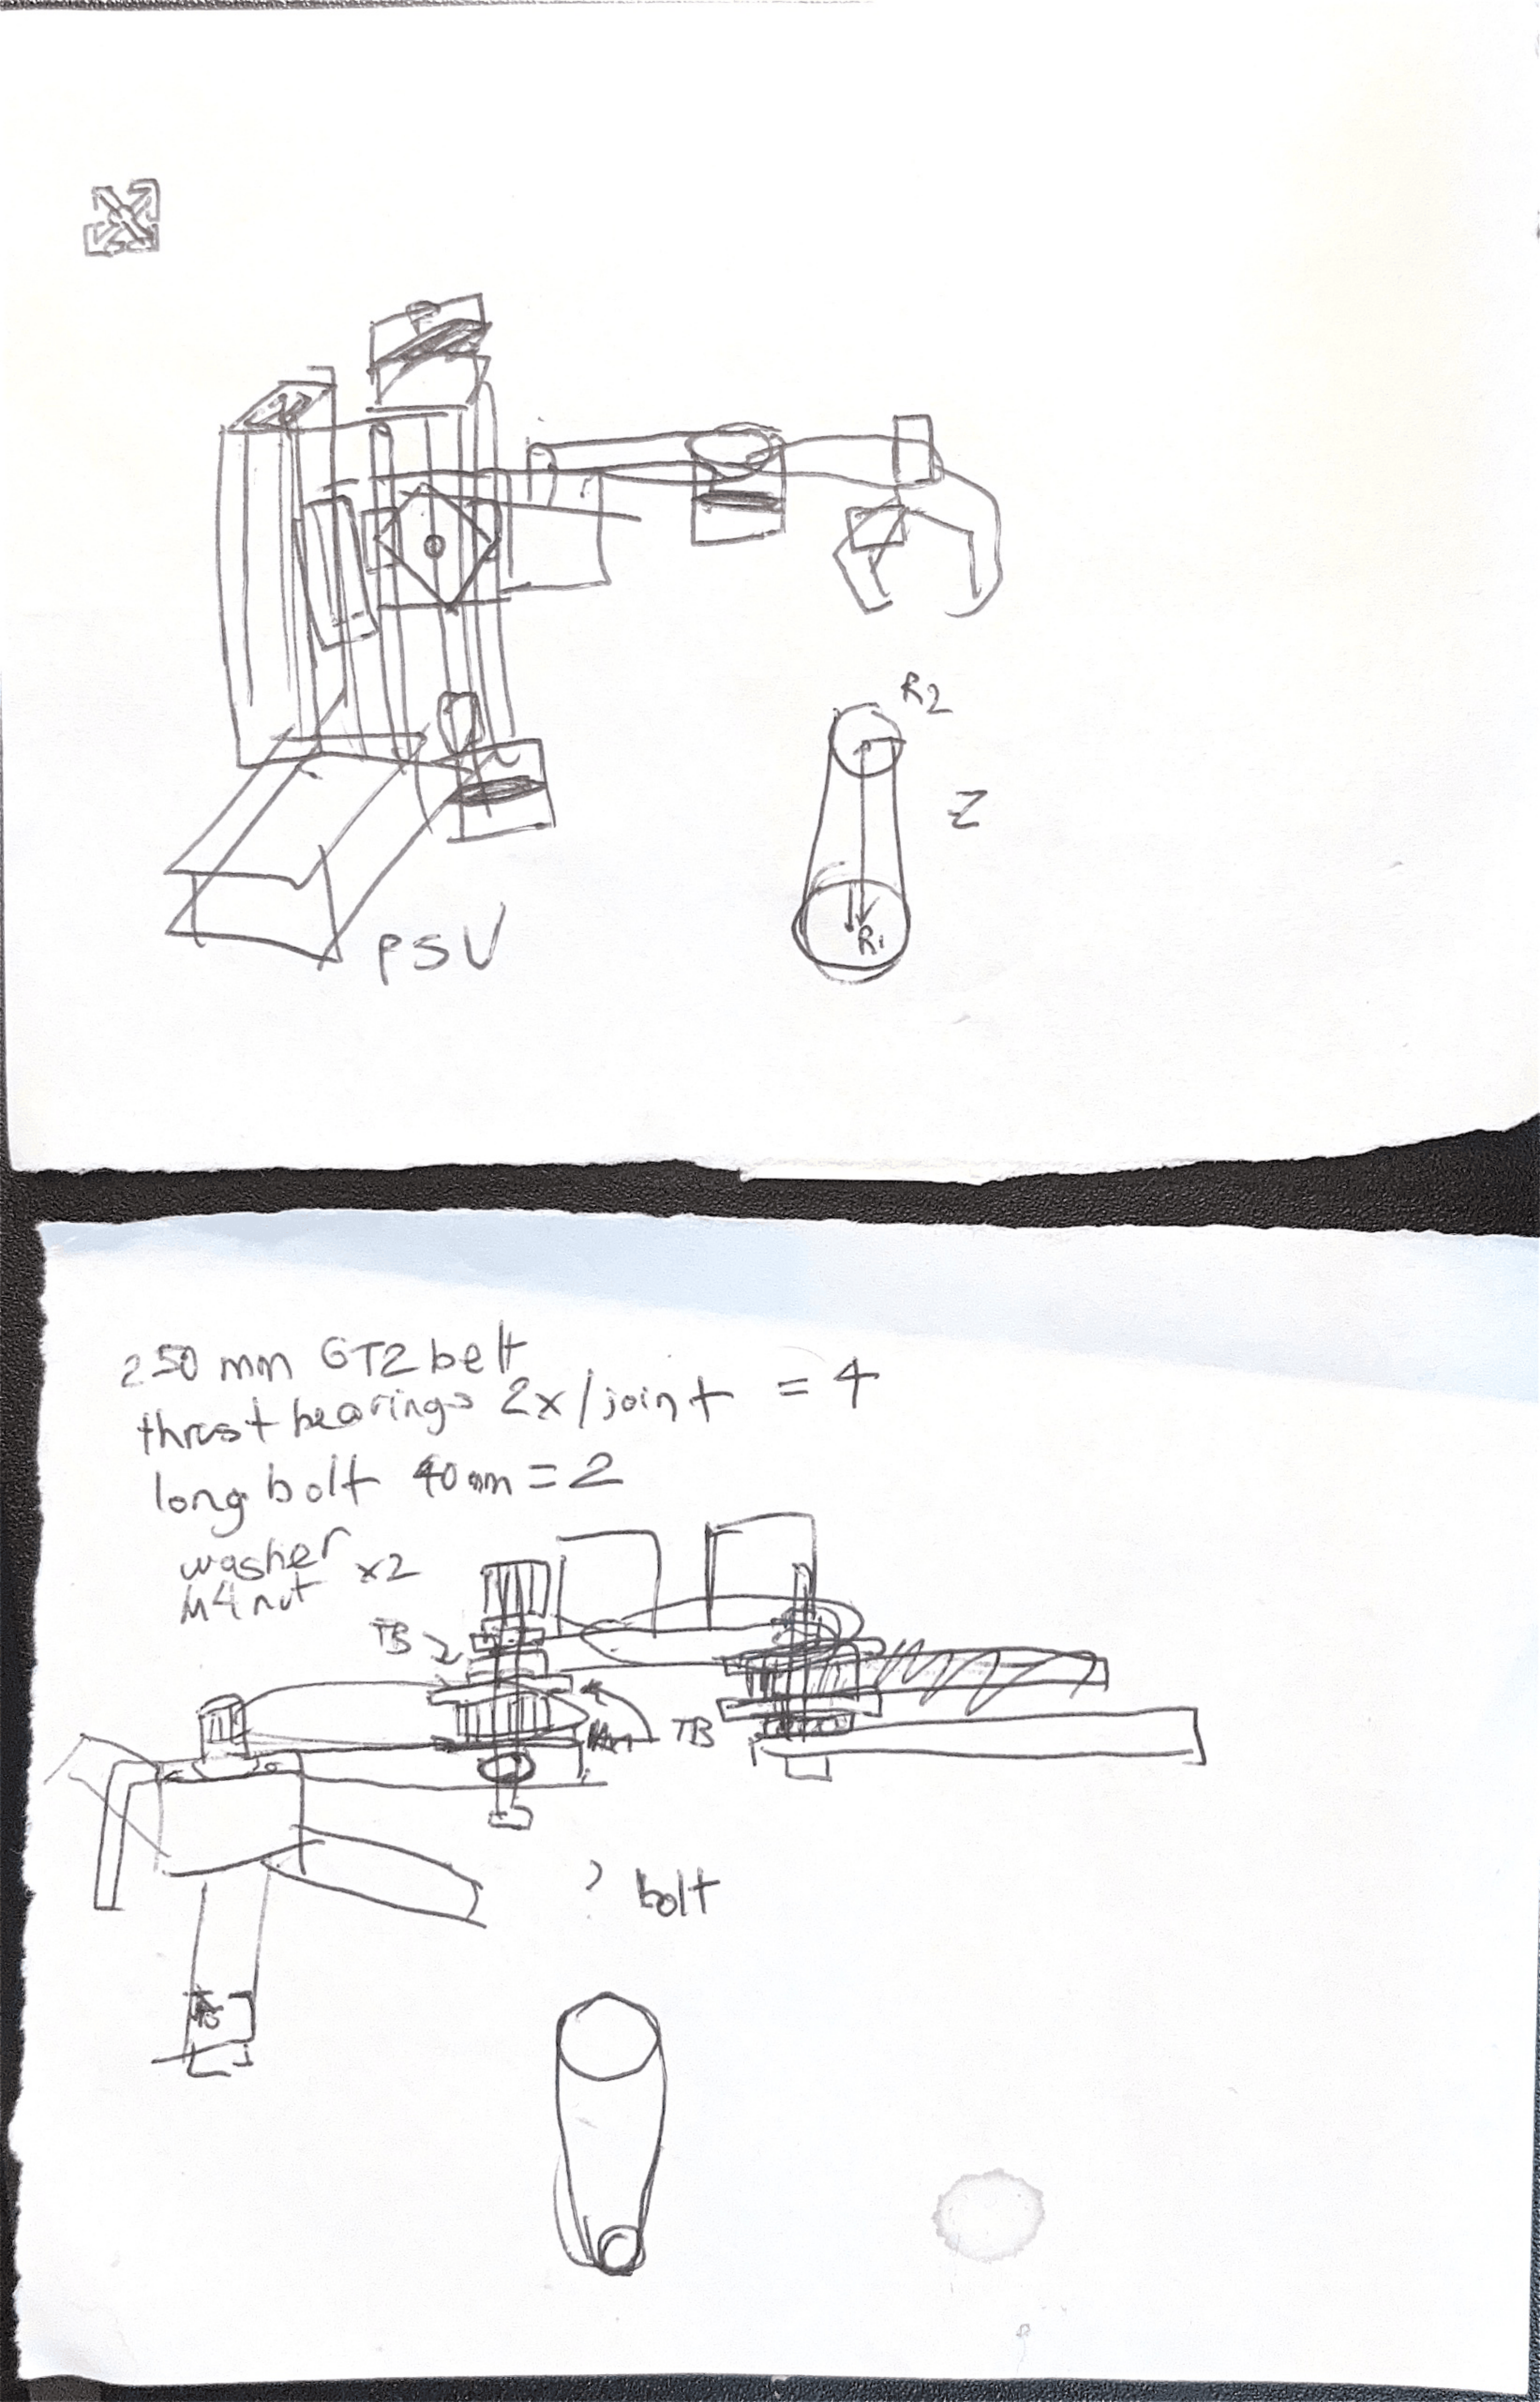
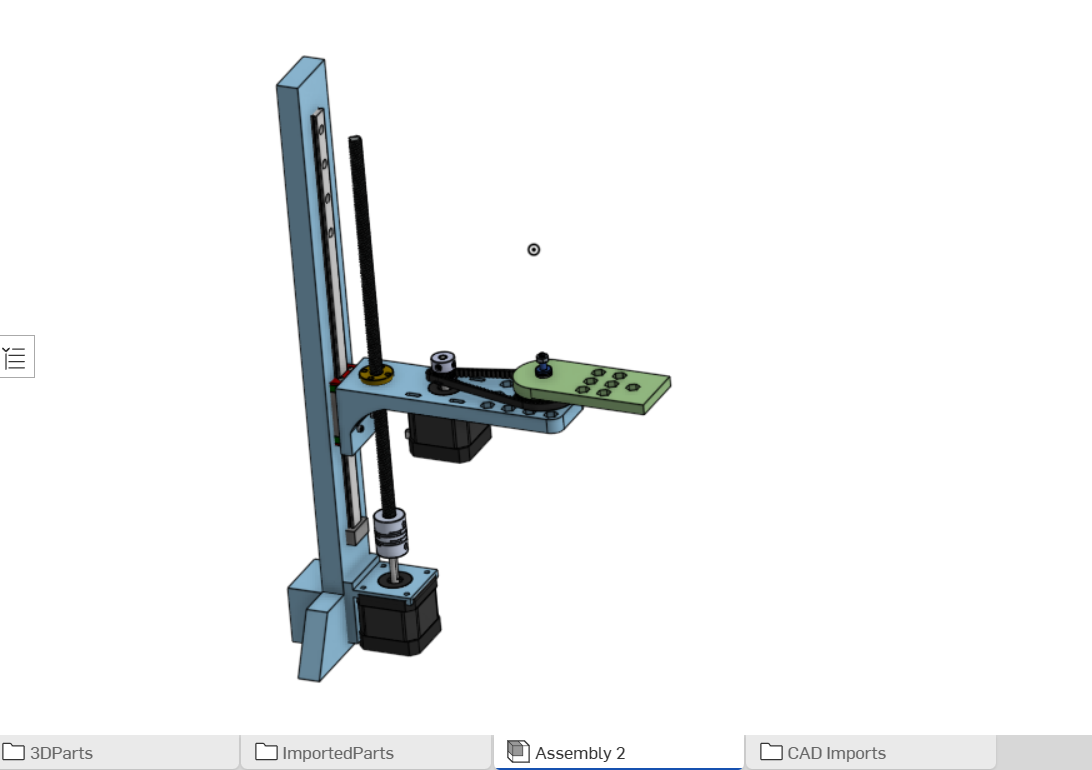
Designed and built a small-scale SCARA robot arm with a 5:1 reduction.
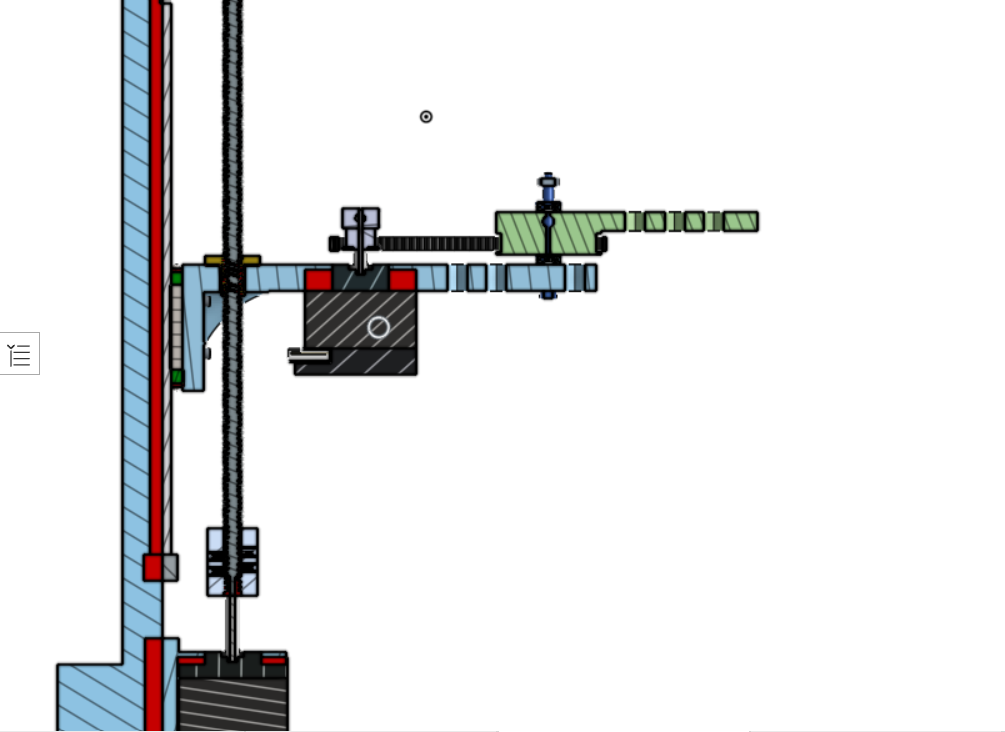
The shoulder movement is a NEMA 17 stepper motor with a GT2 timing belt.
The controls are done with an Arduino Uno and a CNC shield.
The z-axis movement is done through a lead screw and a secondary NEMA 17 stepper.
The arm movement is via a pancake NEMA 17.
Initial Sketches
CAD Models
What I did
- Modeled the SCARA arm structure and components in Fusion 360
- Printed prototypes in PLA and iterated on tolerances
- Sourced and fitted ball bearings for the joints
- Bench testing still in progress — torque and backlash measurements to come